Post
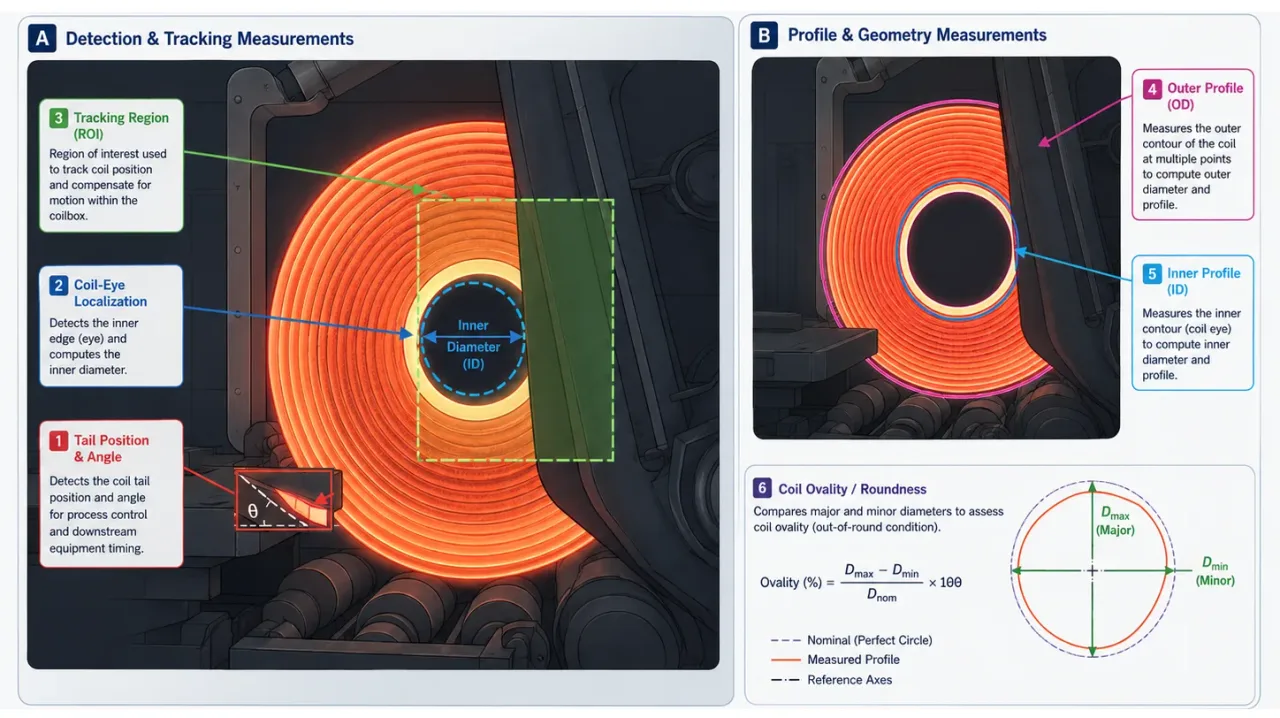
Teaching Steel Industry Equipment to See
A practical look at how AI, computer vision, and deterministic geometry can work together to turn messy real-world perception into reliable measurements a machine can actually use.
End-to-end 3D perception pipeline for automated bin picking using synthetic data and deep learning.
 Ali Maghami
Developed a complete 3D perception pipeline for robotic bin picking applications, leveraging synthetic data generation and deep learning for object localization and grasp planning.
Training data was generated entirely in Blender from CAD, with pre-defined lid, side and bottom pickup regions mapped onto each part and labelled by whether the robot could actually reach them.
To close the gap between synthetic training data and the real bin, every render randomized camera intrinsics and pose, lighting direction, intensity, colour and count, background and environment, object materials, object pose and scene composition, and sensor and image effects.
At run time the RGB keypoint and reachability predictions are lifted onto the colored 3D point cloud to compute a 6DoF frame for each candidate part, which is then scored to propose the next pick.
PyTorch, Mask R-CNN, OpenCV, Open3D, Robot OS (ROS), Blender API, Python